The Bumpy Road to Walking Machines: Why Terrain Still Stumps Robots
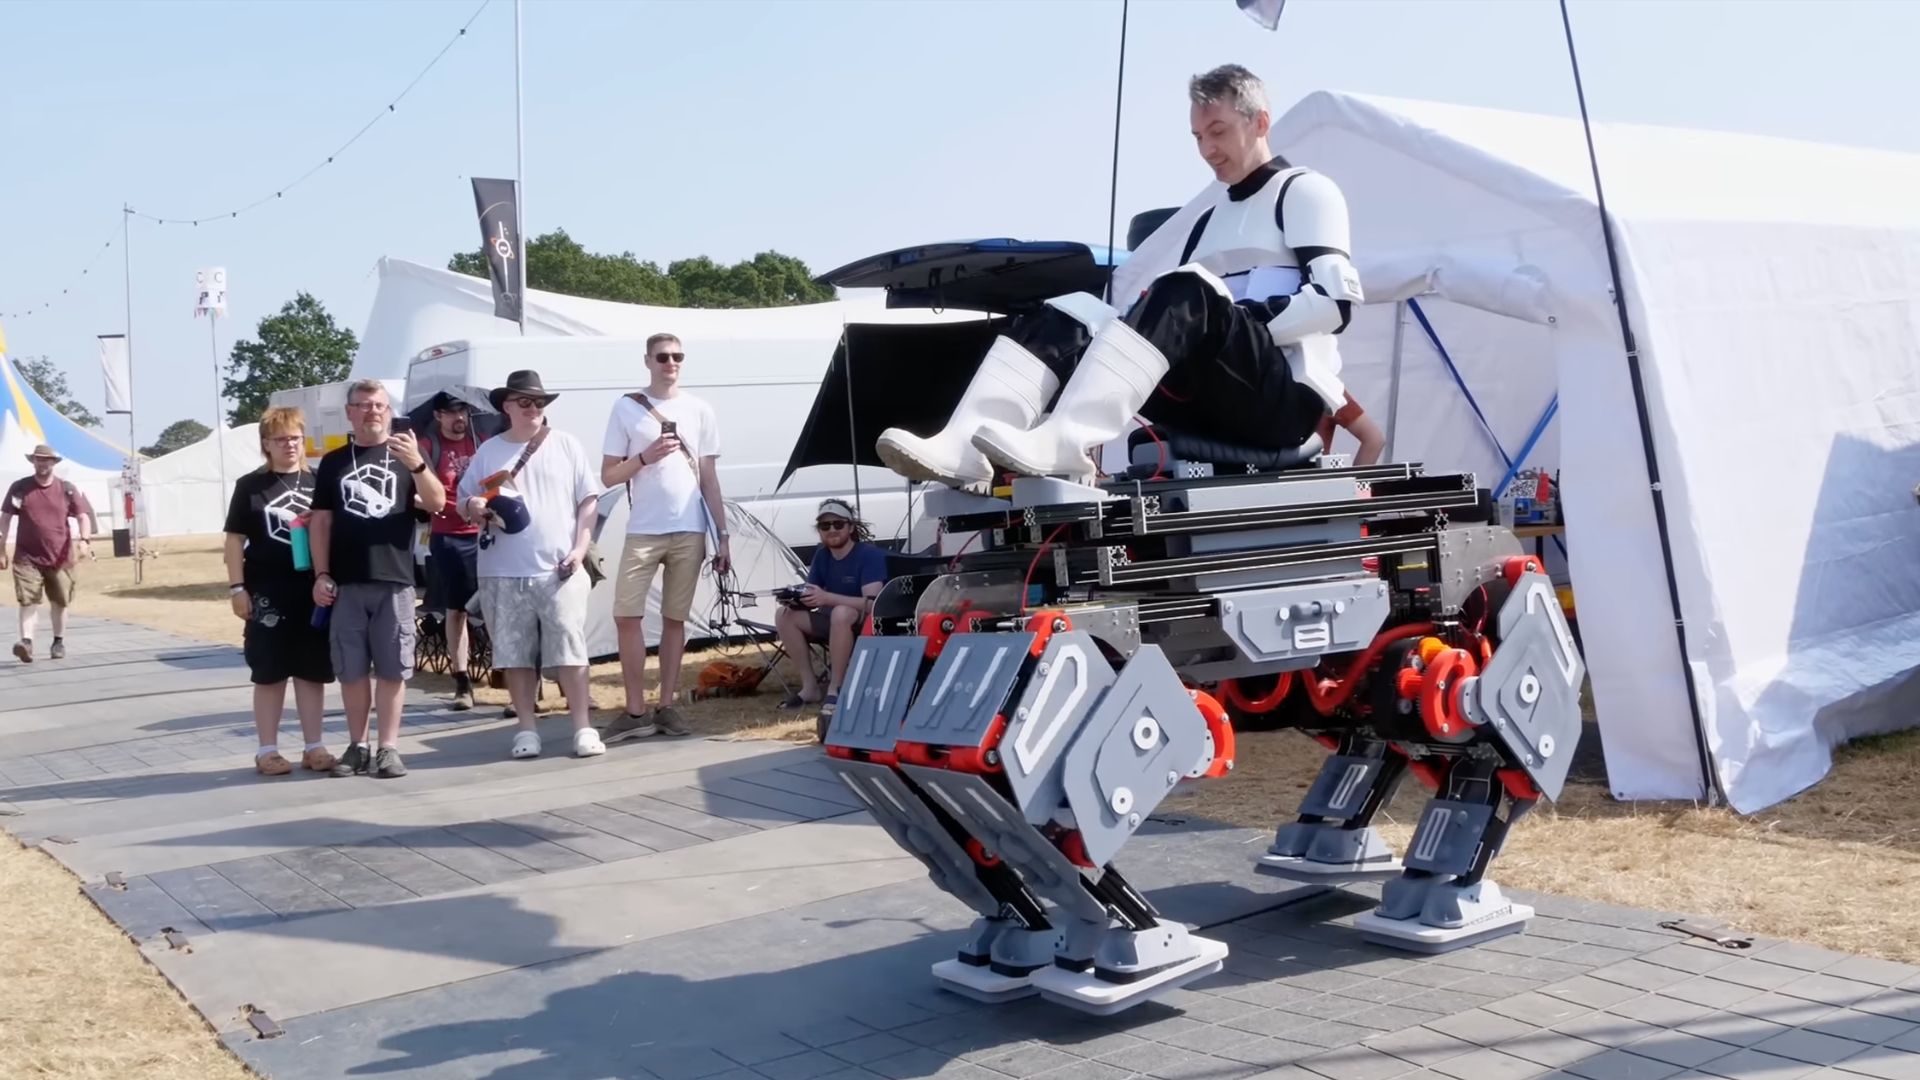
Picture this: You're riding a mechanical horse through a forest, its spindly legs navigating roots and rocks with the grace of a deer. Sounds futuristic, right? James Bruton's Mid-Walker robot brings this vision tantalizingly close—but also exposes a humbling truth about robotics. Watching the machine stumble on uneven ground feels like witnessing a toddler take its first steps: equal parts adorable and frustrating. This isn't just about one inventor's project; it's a microcosm of a century-old engineering dilemma.
The Terrain Problem in Robotics
Let's cut to the chase—why does something as simple as walking remain so damn hard for machines? Bruton's struggles with the Mid-Walker reveal a dirty secret: humans have spent decades mastering controlled environments, but nature laughs at our precision. The robot's ability to handle flat surfaces flawlessly becomes almost comical when it faces a hidden divot. What this really highlights isn't failure, but our species' persistent overconfidence. We build machines that conquer lab conditions, then wonder why they falter in the real world's chaotic beauty.
Bruton's Mechanical Gambit: Simplicity as a Double-Edged Sword
Here's where Bruton shines as both visionary and tinkerer. His decision to mechanically link diagonal legs feels like a rebellious middle finger to AI-obsessed peers. I love this approach—not because it's perfect, but because it dares to ask: How little complexity can we get away with? The sliding seat mechanism, which shifts weight like a cyclist leaning into turns, is pure mechanical poetry. But therein lies the rub: this solution works until it doesn't. The moment the ground plays tricks, even clever physics hits its limits.
Bean Bags and Biomimicry: When Everyday Objects Inspire Robotics
The bean-filled feet might seem whimsical, but they represent something deeper—a fundamental truth about innovation. Bruton didn't look to aerospace materials; he looked at his living room couch. This is what excites me most: the intersection between mundane objects and high-tech problem-solving. Bean bags adapt to human shapes through millions of tiny particles—so why not let robots borrow that trick? The failure here isn't really failure; it's proof that nature's solutions operate on scales we're still learning to mimic.
The Brutal Reality of Field Testing
Let's talk about the elephant in the field: testing at Electromagnetic Field Camp showed something profoundly human about engineering. Bruton's bean-filled feet worked until they encountered terrain that violated his assumptions. Isn't that always the case? We design systems based on our mental models, then reality smacks us with edge cases we never imagined. The curling sole problem—where foot stuffing shifted dangerously—mirrors a universal truth: over-engineering often creates new problems. His iterative approach of half-emptying the beans? Classic hacker ingenuity.
Toward Smarter Feet: Passive Intelligence Over Active Complexity
Now we reach the most fascinating pivot point. Bruton's consideration of BB pellets and vacuum systems feels like watching a chef decide between molecular gastronomy and farm-to-table simplicity. His ultimate choice to pursue passive self-leveling ankles speaks volumes. This isn't just about robotics—it's a philosophical stance. In an era obsessed with adding sensors and AI, Bruton's restraint feels revolutionary. His approach whispers an uncomfortable question to the tech world: Are we overcomplicating things?
The Bigger Picture: Why Walking Machines Matter
So what does this all mean? For me, the Mid-Walker saga crystallizes two competing visions of the future. On one side: hyper-intelligent systems with neural networks and adaptive algorithms. On the other: Bruton's mechanical pragmatism that prioritizes embodied intelligence. The real breakthrough here isn't a specific solution, but the realization that locomotion remains humanity's longest-running design challenge. Every stumble of this quirky robot echoes da Vinci's centuries-old sketches of mechanical knights.
As I reflect on Bruton's journey, I'm struck by a paradox: sometimes progress happens not through revolutionary leaps, but through stubborn persistence in solving deceptively simple problems. The day we perfect terrain-adaptive robotics won't just bring cool gadgets—it'll force us to reexamine what intelligence really means, both artificial and human.